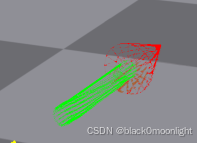
在这里发布一个ISAAC GYM可以使用的箭头绘制类。
gymutil默认有WireframeBoxGeometry,WireframeBBoxGeometry, WireframeSphereGeometry三个线段集生成函数,可以绘制盒子和球体。绘制函数分别有draw_lines和draw_line。
同理,使用以下方法绘制3D箭头:
python
# -*- coding: utf-8 -*-
'''
 ------------------------------------------------------------------
 @File Name:        WireframeGeometry
 @Created:          2024 2024/11/22 16:01
 @Software:         PyCharm

 @Author:           Jiayu ZENG
 @Email:            jiayuzeng@asagi.waseda.jp

 @Description:

 ------------------------------------------------------------------
'''

from __future__ import print_function, division, absolute_import

from abc import ABC, abstractmethod
import math
import numpy as np
import argparse
from bisect import bisect

from isaacgym import gymtorch, gymapi, gymutil
import numpy as np
import math


class WireframeArrowGeometry(gymutil.LineGeometry):
    def __init__(self, start_point, direction, length=1.0, arrow_head_length=0.2, arrow_head_width=0.1, shaft_radius=0.05, shaft_segments=8, pose=None, color=None, color2=None):
        if color is None:
            color = (1, 0, 0)

        if color2 is None:
            color2 = color

        # Normalize direction
        direction = np.array(direction, dtype=float)

        # Calculate main arrow shaft endpoint
        shaft_end_point = start_point + length * direction
        arrow_tip = start_point + (length+arrow_head_length) * direction

        # Arrow shaft
        verts = []
        colors = []

        # Generate perpendicular vectors to direction for shaft
        perp1 = np.cross(direction, np.array([1, 0, 0]))
        if np.linalg.norm(perp1) < 1e-6:
            perp1 = np.cross(direction, np.array([0, 1, 0]))
        perp1 = perp1 / np.linalg.norm(perp1) * shaft_radius

        perp2 = np.cross(direction, perp1)
        perp2 = perp2 / np.linalg.norm(perp2) * shaft_radius

        # Generate shaft lines in a circular pattern
        angle_step = 2 * math.pi / shaft_segments
        shaft_base_points = []
        arrow_base_points = []

        for i in range(shaft_segments):
            angle = i * angle_step
            next_angle = (i + 1) * angle_step

            offset1 = math.cos(angle) * perp1 + math.sin(angle) * perp2
            offset2 = math.cos(next_angle) * perp1 + math.sin(next_angle) * perp2

            start_circle = start_point + offset1
            end_circle = shaft_end_point + offset1
            shaft_base_points.append(end_circle)

            verts.append((start_circle, end_circle))
            colors.append(color)

            verts.append((start_circle, start_point + offset2))
            colors.append(color)

            verts.append((end_circle, shaft_end_point + offset2))
            colors.append(color)

        # Arrow head base point
        arrow_base = shaft_end_point

        # Generate perpendicular vectors to direction for arrow head
        perp1_head = perp1 / shaft_radius * arrow_head_width
        perp2_head = perp2 / shaft_radius * arrow_head_width

        # Generate arrow head lines to represent a cone
        for i in range(shaft_segments):
            angle = i * angle_step
            next_angle = (i + 1) * angle_step

            offset1 = math.cos(angle) * perp1_head + math.sin(angle) * perp2_head
            offset2 = math.cos(next_angle) * perp1_head + math.sin(next_angle) * perp2_head

            base_point1 = arrow_base + offset1
            base_point2 = arrow_base + offset2
            arrow_base_points.append(base_point1)

            # Lines from tip to base circle
            verts.append((arrow_tip, base_point1))
            colors.append(color2)

            # Lines around the base circle
            verts.append((base_point1, base_point2))
            colors.append(color2)

        # Connect corresponding points on the shaft end and arrow base
        for shaft_point, arrow_point in zip(shaft_base_points, arrow_base_points):
            verts.append((shaft_point, arrow_point))
            colors.append(color2)

        # Convert verts and colors to numpy arrays
        num_lines = len(verts)
        verts_np = np.empty((num_lines, 2), gymapi.Vec3.dtype)
        colors_np = np.empty(num_lines, gymapi.Vec3.dtype)

        for idx, (v_start, v_end) in enumerate(verts):
            verts_np[idx][0] = (v_start[0], v_start[1], v_start[2])
            verts_np[idx][1] = (v_end[0], v_end[1], v_end[2])
            colors_np[idx] = colors[idx]

        # Apply pose transformation if provided
        if pose is None:
            self.verts = verts_np
        else:
            self.verts = pose.transform_points(verts_np)

        self._colors = colors_np

    def vertices(self):
        return self.verts

    def colors(self):
        return self._colors
同样调用gymutil.draw_lines绘制。以下代码仅作参考。
python
start_point = np.array([0.0, 0.0, 0.0])
                direction[2] = start_point[2]
                color = (0, 1, 0)
                color2 = (1, 0, 0)
                length *= 0.5
                shaft_radius = 0.02
                shaft_segments = 16
                arrow_head_length = 0.2
                arrow_head_width = shaft_radius * 3
                arrow = WireframeArrowGeometry(start_point, direction, length, arrow_head_length, arrow_head_width,
                                               shaft_radius, shaft_segments, color=color, color2=color2)
                sphere_pose = gymapi.Transform(gymapi.Vec3(pos[0],
                                                           pos[1],
                                                           pos[2] + 0.2), r=None)
                gymutil.draw_lines(arrow, self.gym, self.viewer, env, sphere_pose)
绘制效果: