参考资料
https://gamma.cs.unc.edu/ORCA/publications/ORCA.pdf
https://gamma.cs.unc.edu/RVO2/
数学知识
1.向量的点乘 dotProduct,计算方法:1.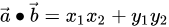 2.
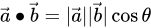 ,
作用:点积如果为负,则a,b形成的角为钝角;如果为零,那么a,b垂直;如果为正,那么a,b形成的角为锐角
2.向量a,向量b,det(a,b)表示行列式的值,计算方法x1y2 - x2y1,同时也是叉乘的值
作用:1.以两个向量为邻边的平行四边形的有向面积,2.小于0表示b在a的顺时针方向,大于0表示b在a逆时针方向,等于0表示a,b平行
下图是碰撞需要修正,并且保证最短修正的两种情况,
-
将速度修正到切线上
-
将速度修正到圆
1,
final double dotProduct1 = w.dotProduct(relativePosition);dotProduct1 < 0.0 && dotProduct1 * dotProduct1 > combinedRadiusSq * wLengthSq这个代码是为了判断当前是哪种情况,
向量w = 相对速度 - 相对位置
dotProduct1小于0,表示向量w与相对位置的夹角为钝角,即AE与AO的角为锐角(需要先判断这个,只有锐角范围内cos单调递减)
dotProduct1 * dotProduct1 > combinedRadiusSq * wLengthSq,角OAE小于角OAD
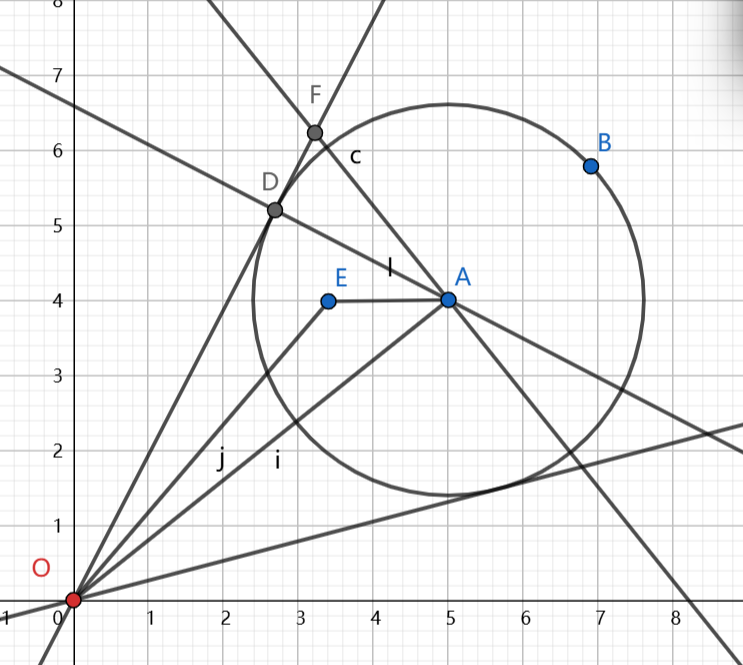
推导:
cos在0-90单调递减
角OAE < 角OAD
=> cosOAE > cosOAD
=> OA*cosOAE > OA*cosOAD (同时乘以OA)
=> OA*cosOAE > AD (OA*cosOAD = AD)
=> OA * AE * cosOAE > AE * AD (同时乘以AE)
=> dotProduct1 * dotProduct1 > combinedRadiusSq * wLengthSq
2
direction = new Vector2D(relativePosition.getX() * leg - relativePosition.getY() * combinedRadius, relativePosition.getX() * combinedRadius + relativePosition.getY() * leg)这段代码为了计算第一情况,修正速度的落点,
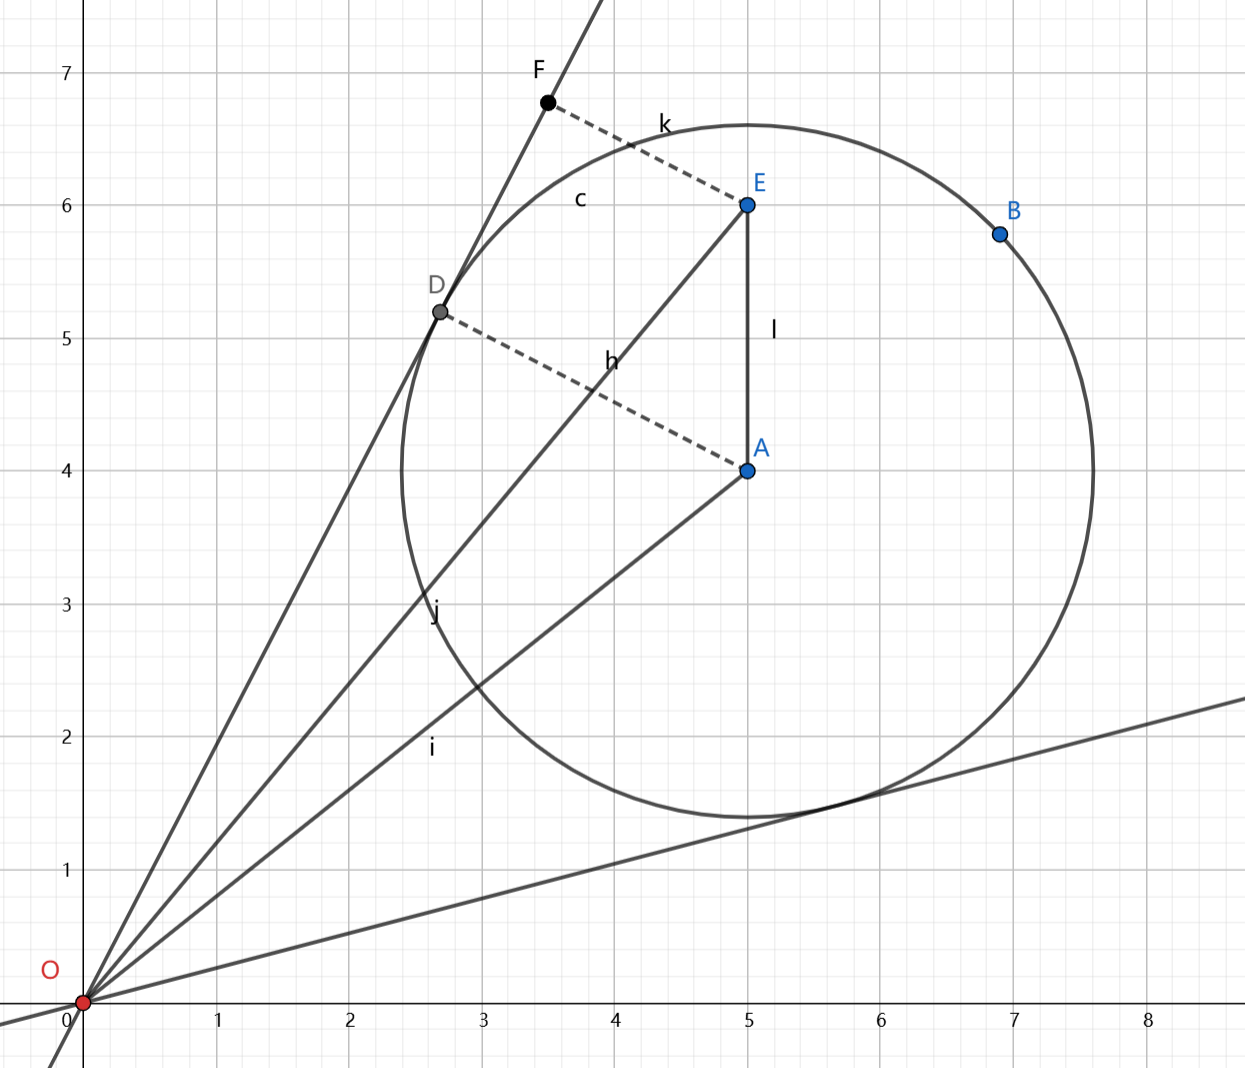
leg为OD的长度,假设direction为line的方向,即向量OD的单位向量DIR(a, b)顺时针的单位向量DIE (b, -a),A的坐标(x, y)
向量OA 点乘 向量DIR = 向量OA的长度 * 1 * cosAOD
=> x*a + y*b = leg
向量OA 点乘 向量DIE = 向量OA的长度 * 1 * cosOAD
=>x*b - y*a = combinedRadius
结合这两个式子就可以解a,b,
RVOMath.det(relativePosition, w) > 0.0这个在判断修正方向是在相对位置的左边还是右边
3
速度的可选区域为line方向的左侧, linearProgram2 找到可行域的交集,即line的交集
3.1
RVOMath.det(lines.get(lineNo).direction, lines.get(lineNo).point.subtract(newVelocity)) > 0.0
大于0说明newVelocity在line的右侧,不在line的可行域内,需要重新计算速度
3.2
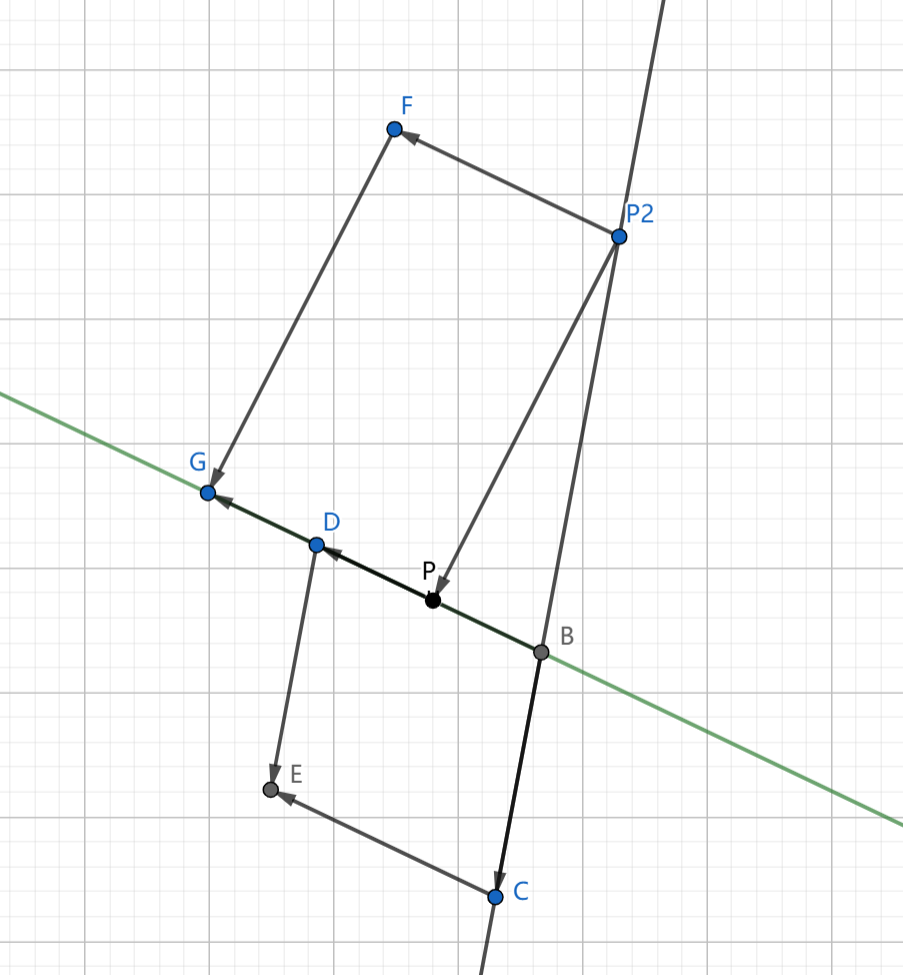
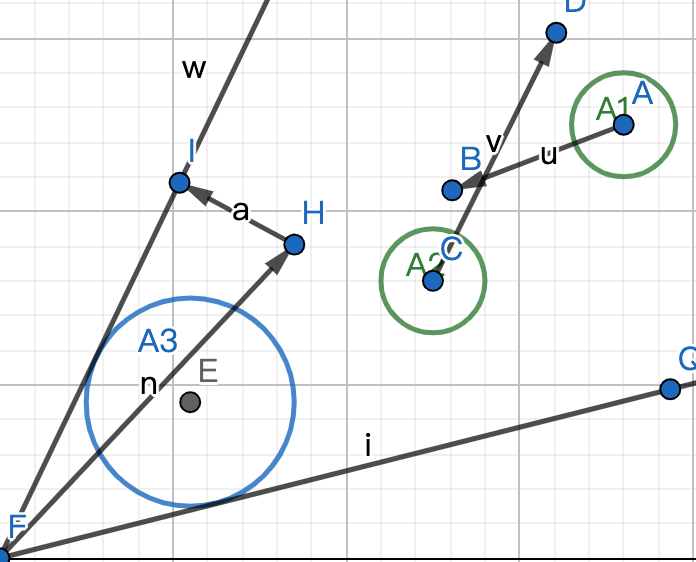
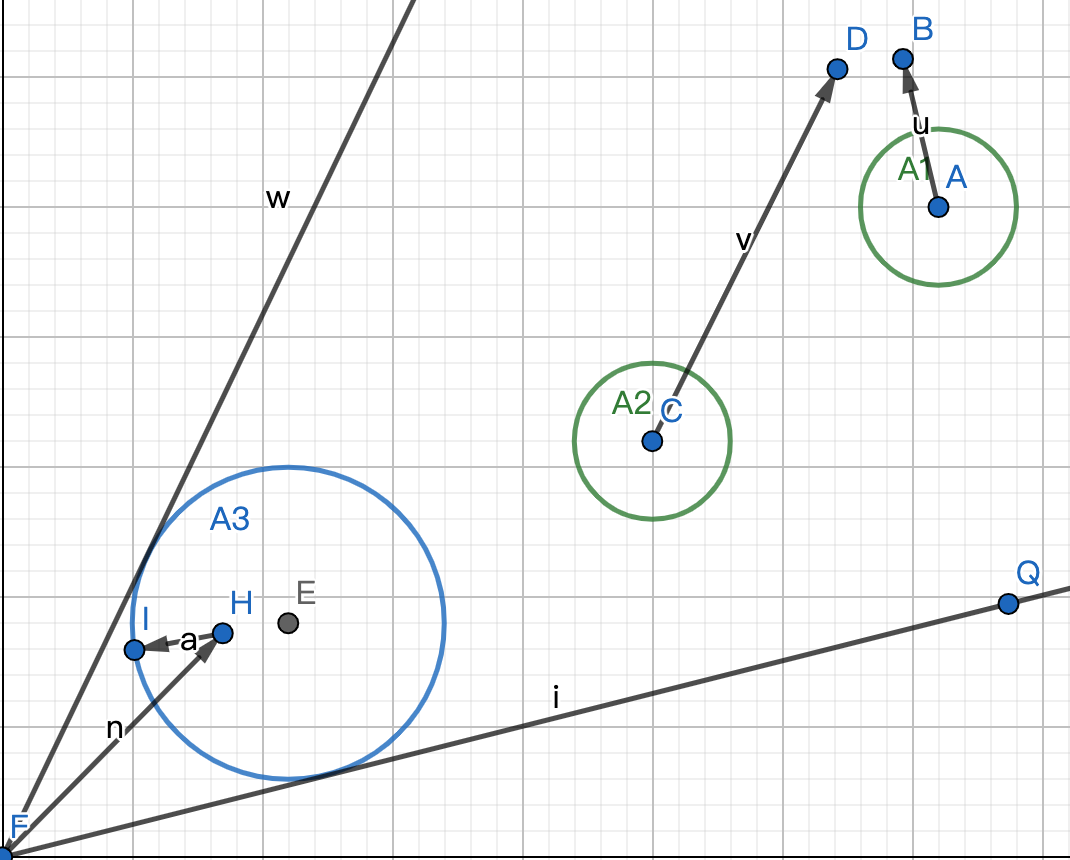
如图,绿色为line i, 黑色为line no
final double denominator = RVOMath.det(lines.get(lineNo).direction, lines.get(i).direction);
final double numerator = RVOMath.det(lines.get(i).direction, lines.get(lineNo).point.subtract(lines.get(i).point));
final double t = numerator / denominator;
denominator为BCED的面积 = 2个DBC的面积 = 2 * 1/2 * BP2 * 高
numerator为PGFP2的面积 = 2个GPP2 的面积 = 2个DBP2的面积 = 2 * 1/2 * BC * 高
t = numerator / denominator = BP2 / BC = BP2
t 为line i 和 line no 的交点 到 line point 的距离
4
linearProgram3
如果找不到line的交集,则执行linearProgram3,从上次失败的line开始往后遍历
将line i 之前的line做一个修正,修正的方法是:(1)将point修正到交点,(2)将方向修正到角平分线,靠近i的方向
RVOMath.det(lines.get(i).direction, lines.get(i).point.subtract(newVelocity)) > distance这段代码用来判断是否需要修正速度,如果修正后的速度与当前line的距离大于前一个line的距离大,那么需要修正。
因为修正后速度将在角平分线上,一定距离当前line更近