PX4固件下载
PX4的源码处于GitHub,因为众所周知的原因git clone经常失败,此处从Gitee获取PX4源码和依赖模块。
git clone https://gitee.com/voima/PX4-Autopilot.git正克隆到 'PX4-Autopilot'...
remote: Enumerating objects: 454209, done.
remote: Total 454209 (delta 0), reused 0 (delta 0), pack-reused 454209
接收对象中: 100% (454209/454209), 215.48 MiB | 2.32 MiB/s, 完成.
处理 delta 中: 100% (334699/334699), 完成.
使用cd命令切换到 px4项目文件目录:
cd ~/PX4-Autopilot使用以下命令切换版本,以V1.14.0为例:
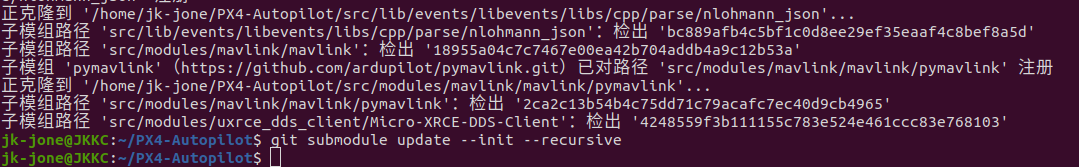
git checkout v1.14.0 #切换到1.14.0分支,当然也可以尝试其他版本因为PX4的完整项目是嵌套子模块存储的,以上命令只下载了px4的基本代码,所以我们要进行子模块的下载,运行下列命令:
git submodule update --init --recursive # 在~/PX4-Autopilot目录下执行以上命令中,submodule是子模块的意思, ---init 选项会初始化,并注册子模块的地址,---recursive选项会递归克隆子模块。
此更新的链接来源于
~/PX4-Autopilot/.gitmodules(注意是隐藏文件)
将文件打开,粘贴到下面,可以看到里面都github的地址,直接用上面的命令,会很难成功
[submodule "src/modules/mavlink/mavlink"] path = src/modules/mavlink/mavlink url = https://github.com/mavlink/mavlink.git branch = master[submodule "src/drivers/uavcan/libuavcan"] path = src/drivers/uavcan/libuavcan url = https://github.com/dronecan/libuavcan.git branch = main[submodule "Tools/simulation/jmavsim/jMAVSim"] path = Tools/simulation/jmavsim/jMAVSim url = https://github.com/PX4/jMAVSim.git branch = main[submodule "Tools/simulation/gazebo-classic/sitl_gazebo-classic"] path = Tools/simulation/gazebo-classic/sitl_gazebo-classic url = https://github.com/PX4/PX4-SITL_gazebo-classic.git branch = main[submodule "src/drivers/gps/devices"] path = src/drivers/gps/devices url = https://github.com/PX4/PX4-GPSDrivers.git branch = main[submodule "platforms/nuttx/NuttX/nuttx"] path = platforms/nuttx/NuttX/nuttx url = https://github.com/PX4/NuttX.git branch = px4_firmware_nuttx-10.3.0+-v1.14[submodule "platforms/nuttx/NuttX/apps"] path = platforms/nuttx/NuttX/apps url = https://github.com/PX4/NuttX-apps.git branch = px4_firmware_nuttx-10.3.0+[submodule "Tools/flightgear_bridge"] path = Tools/simulation/flightgear/flightgear_bridge url = https://github.com/PX4/PX4-FlightGear-Bridge.git[submodule "Tools/simulation/jsbsim/jsbsim_bridge"] path = Tools/simulation/jsbsim/jsbsim_bridge url = https://github.com/PX4/px4-jsbsim-bridge.git[submodule "src/drivers/cyphal/libcanard"] path = src/drivers/cyphal/libcanard url = https://github.com/opencyphal/libcanard.git[submodule "src/drivers/cyphal/public_regulated_data_types"] path = src/drivers/cyphal/public_regulated_data_types url = https://github.com/opencyphal/public_regulated_data_types.git[submodule "src/drivers/cyphal/legacy_data_types"] path = src/drivers/cyphal/legacy_data_types url = https://github.com/PX4/public_regulated_data_types.git branch = legacy[submodule "src/lib/crypto/monocypher"] path = src/lib/crypto/monocypher url = https://github.com/PX4/Monocypher.git branch = px4[submodule "src/lib/events/libevents"] path = src/lib/events/libevents url = https://github.com/mavlink/libevents.git branch = main[submodule "src/lib/crypto/libtomcrypt"] path = src/lib/crypto/libtomcrypt url = https://github.com/PX4/libtomcrypt.git branch = px4[submodule "src/lib/crypto/libtommath"] path = src/lib/crypto/libtommath url = https://github.com/PX4/libtommath.git branch = px4[submodule "src/modules/uxrce_dds_client/Micro-XRCE-DDS-Client"] path = src/modules/uxrce_dds_client/Micro-XRCE-DDS-Client url = https://github.com/PX4/Micro-XRCE-DDS-Client.git branch = px4将其更新为 gitee 的地址,已经整理测试好了,直接替换掉文件的内容即可
[submodule "src/modules/mavlink/mavlink"] path = src/modules/mavlink/mavlink url = https://gitee.com/wtp95/mavlink.git branch = master[submodule "Tools/flightgear_bridge"] path = Tools/simulation/flightgear/flightgear_bridge url = https://gitee.com/seokhb/PX4-FlightGear-Bridge.git[submodule "Tools/simulation/gazebo-classic/sitl_gazebo-classic"] path = Tools/simulation/gazebo-classic/sitl_gazebo-classic url = https://gitee.com/seokhb/PX4-SITL_gazebo-classic.git branch = main[submodule "Tools/simulation/jmavsim/jMAVSim"] path = Tools/simulation/jmavsim/jMAVSim url = https://gitee.com/seokhb/jMAVSim.git branch = main[submodule "Tools/simulation/jsbsim/jsbsim_bridge"] path = Tools/simulation/jsbsim/jsbsim_bridge url = https://gitee.com/seokhb/px4-jsbsim-bridge.git[submodule "platforms/nuttx/NuttX/apps"] path = platforms/nuttx/NuttX/apps url = https://gitee.com/seokhb/NuttX-apps.git branch = px4_firmware_nuttx-10.3.0+[submodule "platforms/nuttx/NuttX/nuttx"] path = platforms/nuttx/NuttX/nuttx url = https://gitee.com/seokhb/NuttX.git branch = px4_firmware_nuttx-10.3.0+-v1.14[submodule "src/drivers/cyphal/public_regulated_data_types"] path = src/drivers/cyphal/public_regulated_data_types url = https://gitee.com/seokhb/public_regulated_data_types.git[submodule "src/drivers/cyphal/legacy_data_types"] path = src/drivers/cyphal/legacy_data_types url = https://gitee.com/jiyuanwangxs/legacy_data_types.git branch = legacy[submodule "src/drivers/cyphal/libcanard"] path = src/drivers/cyphal/libcanard url = https://gitee.com/seokhb/libcanard.git[submodule "src/drivers/gps/devices"] path = src/drivers/gps/devices url = https://gitee.com/seokhb/PX4-GPSDrivers.git branch = main[submodule "src/drivers/uavcan/libuavcan"] path = src/drivers/uavcan/libuavcan url = https://gitee.com/seokhb/libuavcan.git[submodule "src/lib/crypto/libtomcrypt"] path = src/lib/crypto/libtomcrypt url = https://gitee.com/seokhb/libtomcrypt.git branch = px4[submodule "src/lib/crypto/libtommath"] path = src/lib/crypto/libtommath url = https://gitee.com/seokhb/libtommath.git branch = px4[submodule "src/lib/crypto/monocypher"] path = src/lib/crypto/monocypher url = https://gitee.com/seokhb/Monocypher.git branch = px4[submodule "src/lib/events/libevents"] path = src/lib/events/libevents url = https://gitee.com/seokhb/libevents.git branch = main[submodule "src/modules/uxrce_dds_client/Micro-XRCE-DDS-Client"] path = src/modules/uxrce_dds_client/Micro-XRCE-DDS-Client url = https://gitee.com/seokhb/Micro-XRCE-DDS-Client.git branch = px4然后执行下面的命令,就可以
git submodule update --init --recursive有的子模块还是走的github,失败了就多试几次,直到用上面命令不再下载东西了就可以了