此示例是 Intel RealSense 相机与 OpenCV 集成的 "Hello World" 基础代码。示例将打开一个 OpenCV 的 UI 窗口,并将彩色化的深度流渲染到窗口中。以下代码片段演示了如何从 rs2::frame 创建 cv::Mat:
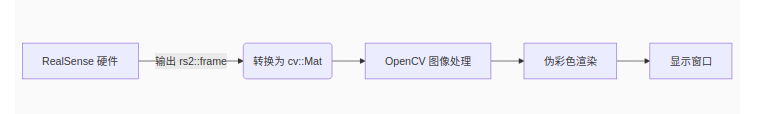
cpp
// License: Apache 2.0. See LICENSE file in root directory.
// Copyright(c) 2017 Intel Corporation. All Rights Reserved.

#include <librealsense2/rs.hpp> // Include RealSense Cross Platform API
#include <opencv2/opencv.hpp>   // Include OpenCV API

int main(int argc, char * argv[]) try
{
    // Declare depth colorizer for pretty visualization of depth data
    // 建着色过滤器(Colorizer Filter)
    // 该过滤器根据输入的深度帧生成彩色图像。
    // 与直接使用OpenCV的区别,RealSense Colorizer	硬件加速、低延迟	依赖RealSense SDK
    // cv::applyColorMap()	跨平台、可定制	需手动处理深度值归一化
    rs2::colorizer color_map;

    // Declare RealSense pipeline, encapsulating the actual device and sensors
    rs2::pipeline pipe;
    // Start streaming with default recommended configuration
    pipe.start();

    using namespace cv;
    const auto window_name = "Display Image";
    namedWindow(window_name, WINDOW_AUTOSIZE);

    while (waitKey(1) < 0 && getWindowProperty(window_name, WND_PROP_AUTOSIZE) >= 0)
    {
        rs2::frameset data = pipe.wait_for_frames(); // Wait for next set of frames from the camera
        rs2::frame depth = data.get_depth_frame().apply_filter(color_map);

        // Query frame size (width and height)
        // 返回图像的像素高度
        const int w = depth.as<rs2::video_frame>().get_width();
        const int h = depth.as<rs2::video_frame>().get_height();

        // Create OpenCV matrix of size (w,h) from the colorized depth data
        Mat image(Size(w, h), CV_8UC3, (void*)depth.get_data(), Mat::AUTO_STEP);

        // Update the window with new data
        imshow(window_name, image);
    }

    return EXIT_SUCCESS;
}
catch (const rs2::error & e)
{
    std::cerr << "RealSense error calling " << e.get_failed_function() << "(" << e.get_failed_args() << "):\n    " << e.what() << std::endl;
    return EXIT_FAILURE;
}
catch (const std::exception& e)
{
    std::cerr << e.what() << std::endl;
    return EXIT_FAILURE;
}
此外,上面手动转换image如果是彩色图像色值会有问题,可以直接使用realsense提供的转换接口:
cpp
// License: Apache 2.0. See LICENSE file in root directory.
// Copyright(c) 2017 Intel Corporation. All Rights Reserved.

#include <librealsense2/rs.hpp> // Include RealSense Cross Platform API
#include <opencv2/opencv.hpp>   // Include OpenCV API
#include "../cv-helpers.hpp"
int main(int argc, char * argv[]) try
{
    // Declare depth colorizer for pretty visualization of depth data
    // 建着色过滤器(Colorizer Filter)
    // 该过滤器根据输入的深度帧生成彩色图像。
    // 与直接使用OpenCV的区别,RealSense Colorizer	硬件加速、低延迟	依赖RealSense SDK
    // cv::applyColorMap()	跨平台、可定制	需手动处理深度值归一化
    rs2::colorizer color_map;

    // Declare RealSense pipeline, encapsulating the actual device and sensors
    rs2::pipeline pipe;
    // Start streaming with default recommended configuration
    pipe.start();

    using namespace cv;
    const auto window_name = "Display Image";
    namedWindow(window_name, WINDOW_AUTOSIZE);

    while (waitKey(1) < 0 && getWindowProperty(window_name, WND_PROP_AUTOSIZE) >= 0)
    {
        rs2::frameset data = pipe.wait_for_frames(); // Wait for next set of frames from the camera
        rs2::frame depth = data.get_depth_frame().apply_filter(color_map);
        rs2::frame color = data.get_color_frame();
        // Query frame size (width and height)
        // 返回图像的像素高度
        const int w = depth.as<rs2::video_frame>().get_width();
        const int h = depth.as<rs2::video_frame>().get_height();
        const int cw = color.as<rs2::video_frame>().get_width();
        const int ch = color.as<rs2::video_frame>().get_height();

        // Create OpenCV matrix of size (w,h) from the colorized depth data
        //Mat image(Size(w, h), CV_8UC3, (void*)depth.get_data(), Mat::AUTO_STEP);
        Mat image = frame_to_mat(depth);
        // Update the window with new data
        imshow(window_name, image);
    }

    return EXIT_SUCCESS;
}
catch (const rs2::error & e)
{
    std::cerr << "RealSense error calling " << e.get_failed_function() << "(" << e.get_failed_args() << "):\n    " << e.what() << std::endl;
    return EXIT_FAILURE;
}
catch (const std::exception& e)
{
    std::cerr << e.what() << std::endl;
    return EXIT_FAILURE;
}