文章目录
- 一、说明
- [二、什么是Lucas-Kanade 方法](#二、什么是Lucas-Kanade 方法)
- [三、Lucas-Kanade 原理](#三、Lucas-Kanade 原理)
- 四、代码实现
-
- [4.1 第 1 步:用户在第一帧绘制一个矩形](#4.1 第 1 步:用户在第一帧绘制一个矩形)
- [4.2 第 2 步:从图像中提取关键点](#4.2 第 2 步:从图像中提取关键点)
- [4.3 第 3 步:跟踪每一帧的关键点](#4.3 第 3 步:跟踪每一帧的关键点)
一、说明
本文针对基于光流法的目标追踪进行叙述,首先介绍Lucas-Kanade 方法的引进,以及基本推导,然后演示如何实现光流法的运动跟踪。并以OpenCV实现一个基本项目。
二、什么是Lucas-Kanade 方法
在计算机视觉领域,Lucas-Kanade 方法是 Bruce D. Lucas 和Takeo Kanade开发的一种广泛使用的光流估计差分方法。该方法假设所考虑像素局部邻域中的光流基本恒定,并根据最小二乘准则求解该邻域中所有像素的基本光流方程。
通过结合来自多个邻近像素的信息,Lucas-Kanade 方法通常可以解决光流方程固有的模糊性。与逐点方法相比,该方法对图像噪声的敏感度也较低。另一方面,由于它是一种纯局部方法,因此无法提供图像均匀区域内部的流信息。
三、Lucas-Kanade 原理
在理论上,初始时间为 t 0 t_0 t0 时刻,经历过 Δ t \Delta t Δt时段后,点p会移动到另一个位置 p ′ p′ p′ ,并且 p ′ p′ p′ 本身和周围都有着与p相似的亮度值。朴素的LK光流法是直接用灰度值代替RGB作为亮度。根据上面的描述,对于点p而言,假设p 的坐标值是( x , y ),有
I ( x , y , t ) = I ( x + Δ x , y + Δ y , t + Δ t ) I(x, y, t) = I(x+\Delta x,y+\Delta y, t+\Delta t) I(x,y,t)=I(x+Δx,y+Δy,t+Δt)
根据泰勒公式:在这里把x 、y 看做是t 的函数,把公式(1)看做单变量t 的等式,只需对t进行展开)
I ( x , y , t ) = I ( x , y , t ) + ∂ I ∂ x ∂ x ∂ t + ∂ I ∂ y ∂ y ∂ t + ∂ I ∂ t + o ( Δ t ) I(x,y,t)=I(x,y,t)+\frac{∂I} {∂x}\frac{∂x}{∂t}+\frac{∂I} {∂y}\frac{∂y}{∂t}+\frac{∂I} {∂t}+o(Δt) I(x,y,t)=I(x,y,t)+∂x∂I∂t∂x+∂y∂I∂t∂y+∂t∂I+o(Δt)
对于一个像素区域:
I x ( q 1 ) V x + I y ( q 1 ) V x = − I t ( q 1 ) I x ( q 2 ) V x + I y ( q 2 ) V x = − I t ( q 2 ) . . . I x ( q n ) V x + I y ( q n ) V x = − I t ( q n ) I_x(q_1)V_x+I_y(q_1)V_x=-I_t(q_1)\\I_x(q_2)V_x+I_y(q_2)V_x=-I_t(q_2)\\...\\I_x(q_n)V_x+I_y(q_n)V_x=-I_t(q_n) Ix(q1)Vx+Iy(q1)Vx=−It(q1)Ix(q2)Vx+Iy(q2)Vx=−It(q2)...Ix(qn)Vx+Iy(qn)Vx=−It(qn)
在这里: q 1 , q 2 , . . . q n q_1,q_2,...q_n q1,q2,...qn是窗口内点的标号, I x ( q i ) I_x(q_i) Ix(qi), I y ( q i ) I_y(q_i) Iy(qi), I t ( q i ) I_t(q_i) It(qi)是图像的灰度偏导数,
这些方程可以写成矩阵形式:
A v = b Av=b Av=b

这个系统的方程多于未知数,因此它通常是过度确定的。Lucas-Kanade方法通过最小二乘原理得到折衷解。也就是说,它解决了2×2系统:

或

因此

四、代码实现
4.1 第 1 步:用户在第一帧绘制一个矩形
bash
# Path to video
video_path="videos/bicycle1.mp4"
video = cv2.VideoCapture(video_path)

# read only the first frame for drawing a rectangle for the desired object
ret,frame = video.read()

# I am giving  big random numbers for x_min and y_min because if you initialize them as zeros whatever coordinate you go minimum will be zero
x_min,y_min,x_max,y_max=36000,36000,0,0


def coordinat_chooser(event,x,y,flags,param):
    global go , x_min , y_min, x_max , y_max

    # when you click the right button, it will provide coordinates for variables
    if event==cv2.EVENT_RBUTTONDOWN:

        # if current coordinate of x lower than the x_min it will be new x_min , same rules apply for y_min
        x_min=min(x,x_min)
        y_min=min(y,y_min)

         # if current coordinate of x higher than the x_max it will be new x_max , same rules apply for y_max
        x_max=max(x,x_max)
        y_max=max(y,y_max)

        # draw rectangle
        cv2.rectangle(frame,(x_min,y_min),(x_max,y_max),(0,255,0),1)


    """
        if you didn't like your rectangle (maybe if you made some misclicks),  reset the coordinates with the middle button of your mouse
        if you press the middle button of your mouse coordinates will reset and you can give a new 2-point pair for your rectangle
    """
    if event==cv2.EVENT_MBUTTONDOWN:
        print("reset coordinate  data")
        x_min,y_min,x_max,y_max=36000,36000,0,0

cv2.namedWindow('coordinate_screen')
# Set mouse handler for the specified window, in this case, "coordinate_screen" window
cv2.setMouseCallback('coordinate_screen',coordinat_chooser)


while True:
    cv2.imshow("coordinate_screen",frame) # show only first frame

    k = cv2.waitKey(5) & 0xFF # after drawing rectangle press ESC
    if k == 27:
        cv2.destroyAllWindows()
        break


cv2.destroyAllWindows()
4.2 第 2 步:从图像中提取关键点
bash
# take region of interest ( take inside of rectangle )
roi_image=frame[y_min:y_max,x_min:x_max]

# convert roi to grayscale
roi_gray=cv2.cvtColor(roi_image,cv2.COLOR_BGR2GRAY)

# Params for corner detection
feature_params = dict(maxCorners=20,  # We want only one feature
                      qualityLevel=0.2,  # Quality threshold
                      minDistance=7,  # Max distance between corners, not important in this case because we only use 1 corner
                      blockSize=7)

first_gray = cv2.cvtColor(frame,cv2.COLOR_BGR2GRAY)

# Harris Corner detection
points = cv2.goodFeaturesToTrack(first_gray, mask=None, **feature_params)


# Filter the detected points to find one within the bounding box
for point in points:
    x, y = point.ravel()
    if y_min <= y <= y_max and x_min <= x <= x_max:
        selected_point = point
        break

# If a point is found, convert it to the correct shape
if selected_point is not None:
    p0 = np.array([selected_point], dtype=np.float32)

plt.imshow(roi_gray,cmap="gray")
将从此图像中提取关键点
4.3 第 3 步:跟踪每一帧的关键点
bash
############################ Parameters ####################################

"""
winSize --> size of the search window at each pyramid level
Smaller windows can more precisely track small, detailed features -->   slow or subtle movements and where fine detail tracking is crucial.
Larger windows is better for larger displacements between frames ,  more robust to noise and small variations in pixel intensity --> require more computations
"""

# Parameters for Lucas-Kanade optical flow
lk_params = dict(winSize=(7, 7),  # Window size
                 maxLevel=2,  # Number of pyramid levels
                 criteria=(cv2.TERM_CRITERIA_EPS | cv2.TERM_CRITERIA_COUNT, 10, 0.03))


############################ Algorithm ####################################

# Read video
cap = cv2.VideoCapture(video_path)

# Take first frame and find corners in it
ret, old_frame = cap.read()

width = old_frame.shape[1]
height = old_frame.shape[0]

# Create a mask image for drawing purposes
mask = np.zeros_like(old_frame)

frame_count = 0
start_time = time.time()

old_gray = first_gray

while True:
    ret, frame = cap.read()
    if not ret:
        break

    frame_gray = cv2.cvtColor(frame, cv2.COLOR_BGR2GRAY)

    if p0 is not None:
        # Calculate optical flow
        p1, st, err = cv2.calcOpticalFlowPyrLK(old_gray, frame_gray, p0, None, **lk_params)
        good_new = p1[st == 1]  # st==1 means found point
        good_old = p0[st == 1]


        if len(good_new) > 0:
            # Calculate movement
            a, b = good_new[0].ravel()
            c, d = good_old[0].ravel()

            # Draw the tracks
            mask = cv2.line(mask, (int(a), int(b)), (int(c), int(d)), (0, 255, 0), 2)
            frame = cv2.circle(frame, (int(a), int(b)), 5, (0, 255, 0), -1)

            img = cv2.add(frame, mask)

            # Calculate and display FPS
            elapsed_time = time.time() - start_time
            fps = frame_count / elapsed_time if elapsed_time > 0 else 0
            cv2.putText(img, f"FPS: {fps:.2f}", (width - 200, 30), cv2.FONT_HERSHEY_SIMPLEX, 1, (255, 0, 0), 2, cv2.LINE_AA)

            cv2.imshow('frame', img)

            # Update previous frame and points
            old_gray = frame_gray.copy()
            p0 = good_new.reshape(-1, 1, 2)

        else:
            p0 = None

        # Check if the tracked point is out of frame
        if not (25 <= a < width):
            p0 = None  # Reset p0 to None to detect new feature in the next iteration
            selected_point_distance = 0  # Reset selected point distance when new point is detected


    # Redetect features if necessary
    if p0 is None:
        p0 = cv2.goodFeaturesToTrack(frame_gray, mask=None, **feature_params)
        mask = np.zeros_like(frame)
        selected_point_distance=0

    frame_count += 1

    k = cv2.waitKey(25)
    if k == 27:
        break


cv2.destroyAllWindows()
cap.release()
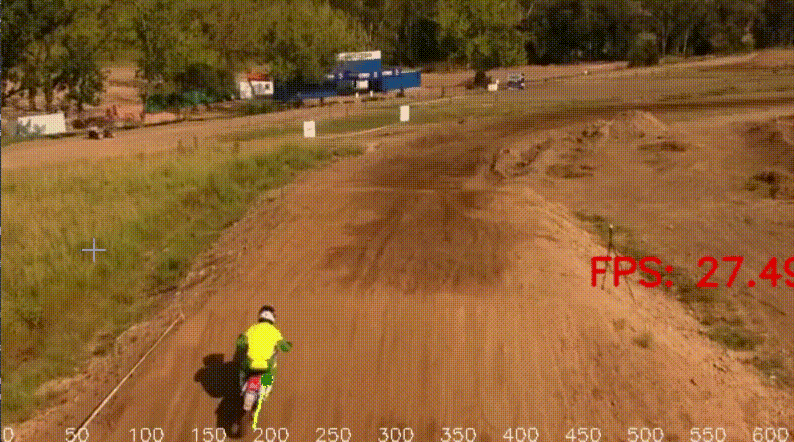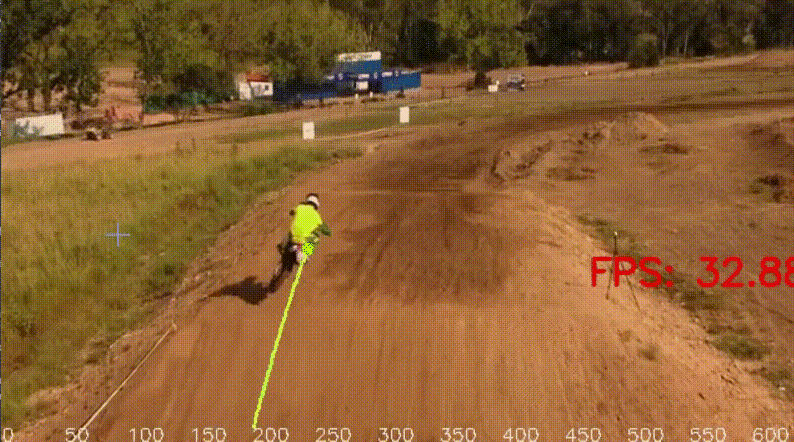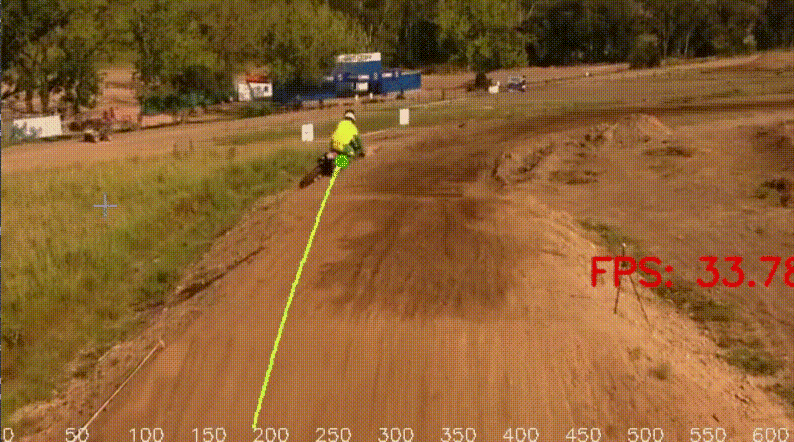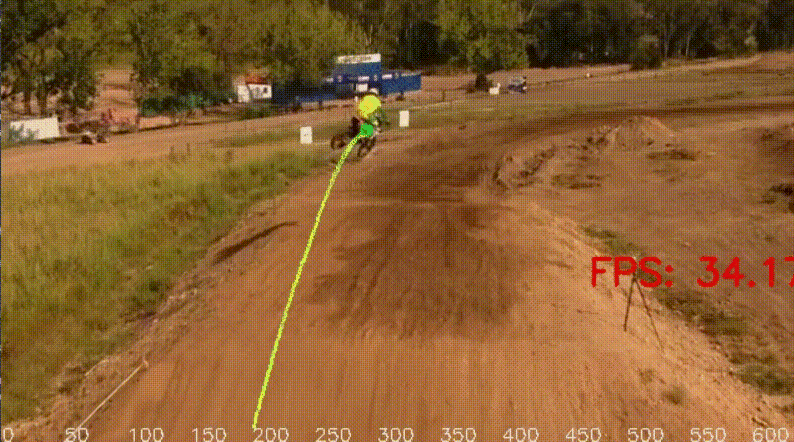
结果